Three control sources, one architecture
A fail-operational drive-by-wire platform for autonomous driving, teleoperation and driver intervention
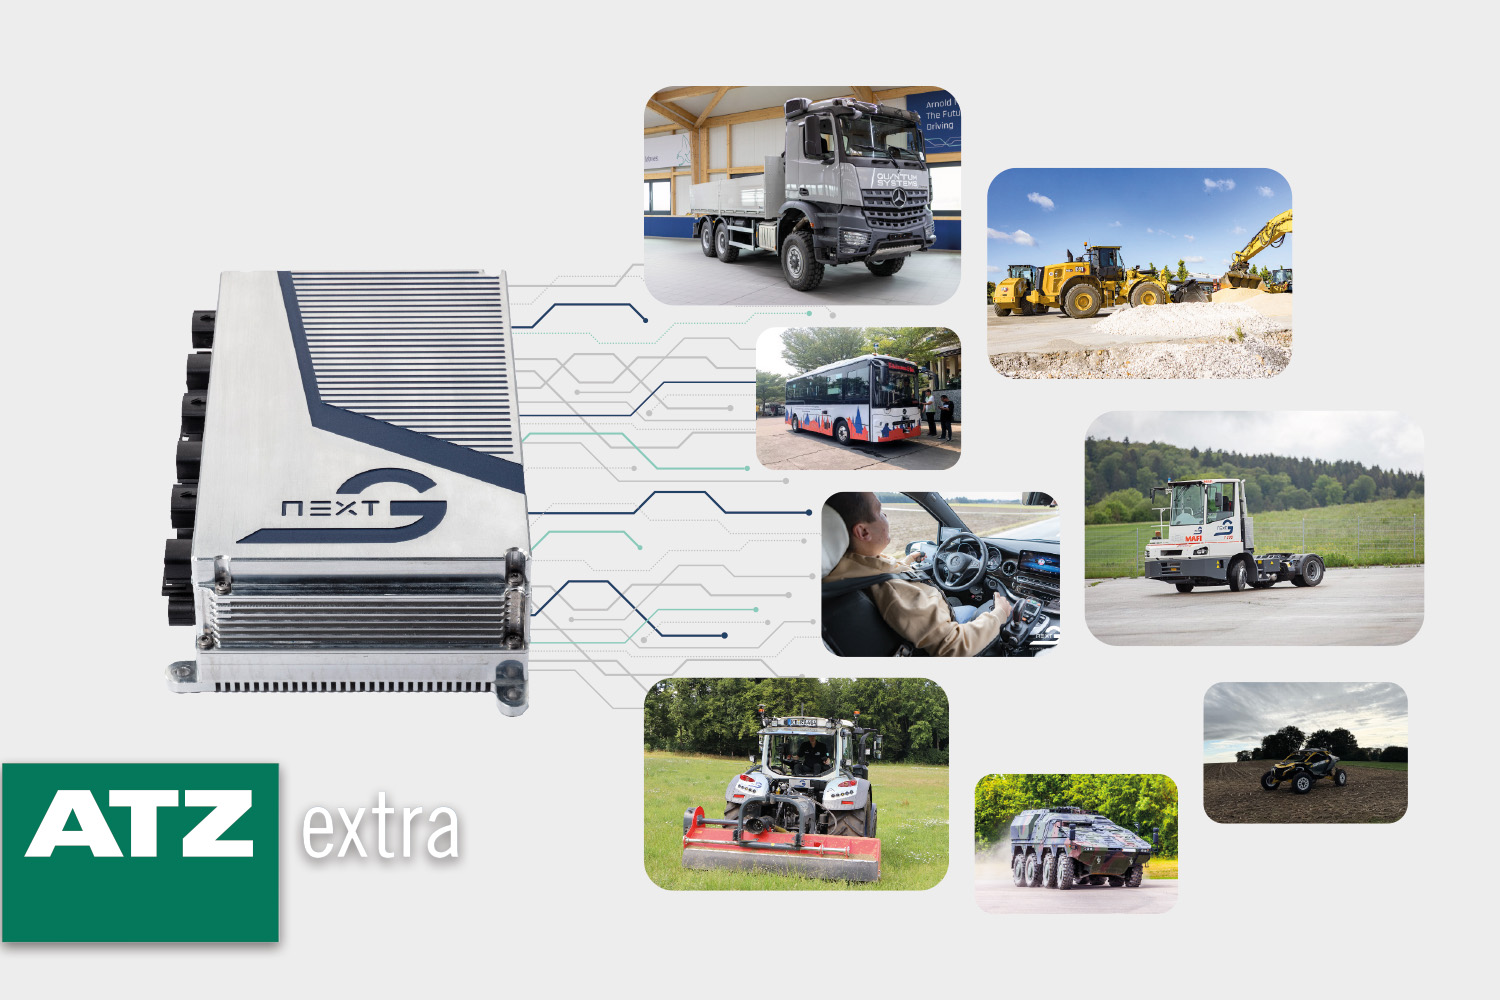
Autonomous driving, teleoperation and driver intervention are often treated as separate operating modes. NX NextMotion™ integrates all three control sources into a unified, multi-redundant drive-by-wire platform designed for use on public roads.
For this architecture, Arnold NextG introduces fully fail-operational as an extended technical working definition: Every safety-critical function, every channel and every power path is designed with redundancy; multiple independent control sources are arbitrated deterministically. This ensures that all safety-critical control functions remain fully available within specified performance and safety limits following any single failure under consideration. Each redundant control channel is designed to meet ASIL D requirements.
The platform can be deployed across vehicle classes, from passenger cars and trucks to off-highway machinery. A tractor capable of autonomous, teleoperated and manual control serves as a demonstrator, illustrating the safe integration and arbitration of the different control sources.
Published in ATZheavy duty 02/2026
The technical article "Three control sources, one architecture" by Danijel Andrijic, Chief Innovation Officer, and Dr Andreas Heitmann, Chief Engineer at the Rüsselsheim site, both at Arnold NextG GmbH, explores the system architecture, safety concept and practical implementation using an autonomous and teleoperated tractor.